 Formada3D
Custom gripper fingers and robot fixtures.
Formada3D designs and 3D prints custom fingertips, fingers and fixtures for robot grippers in Melbourne: part-specific contours, replaceable soft pads and the exact mounting pattern of your gripper. Send the gripper model and a STEP or photo of the part; you get a design with a 3D preview, a printed prototype in 2–3 days and a quote within 1 business day.
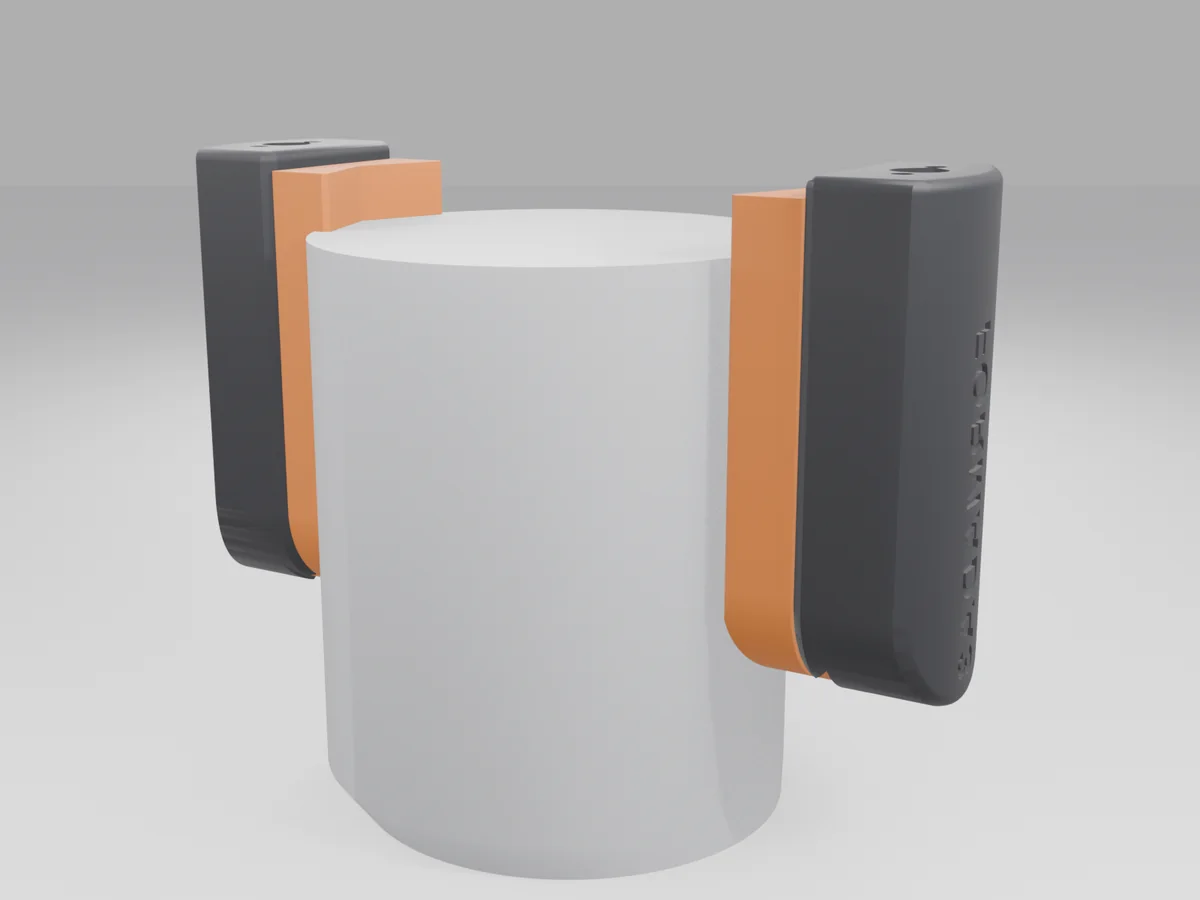
Soft-grip fingertips for a Robotiq 2F-85, designed like a customer job
To show the process end to end we designed a fingertip set for one of the most common cobot grippers, from its public mounting drawings to a print-ready file, the way we would for your part.
- Mount Fits the 2F-85 and 2F-140 finger holder: one M5 screw and two Ø2 mm dowel pins on the 16.2 × 17.8 mm end face, taken from Robotiq’s public instruction manual. A 15 mm mount coupon prints first to confirm the pattern on the real gripper.
- Body PETG-CF, 50 × 22 mm, about 10 g. Barrel back with 45° chamfers, a Ø9.4 mm bore so the screw and a 4 mm hex key go in from the tip. Printed standing on its mount face: no supports, and the mount face comes off the bed flat.
- Pads TPU 95A, two contours: a 140° V-groove that centres Ø40–60 mm round parts on four contact lines, and a flat ribbed face for boxes. Dovetail slide with a snap groove; no glue, no tools.
- Fit Pads are the loose part: a set of four pad coupons (0.15–0.30 mm clearance) is printed with the first set so the slide fit is tuned to the printer, not guessed.
- Not included The M5 screw and dowel pins are the gripper’s own fingertip hardware. Robotiq is a trademark of its owner; we are not affiliated. “Fits” describes the mounting pattern only.
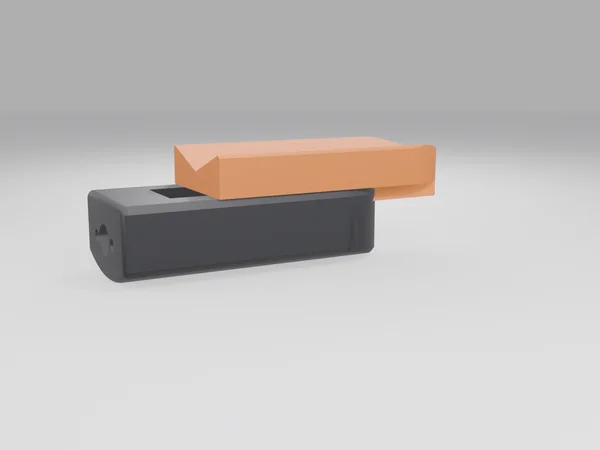
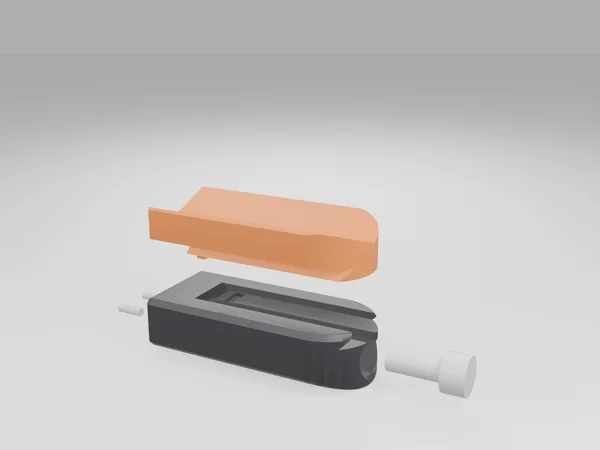
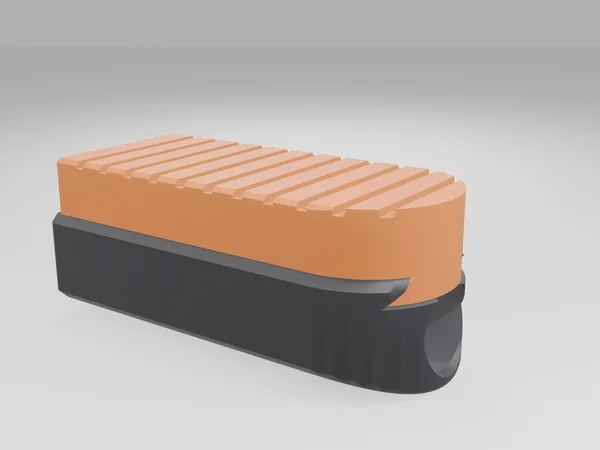
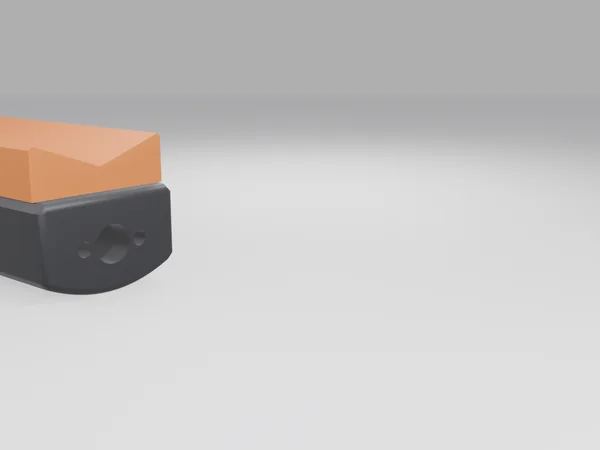
First fit prototype, off the printer
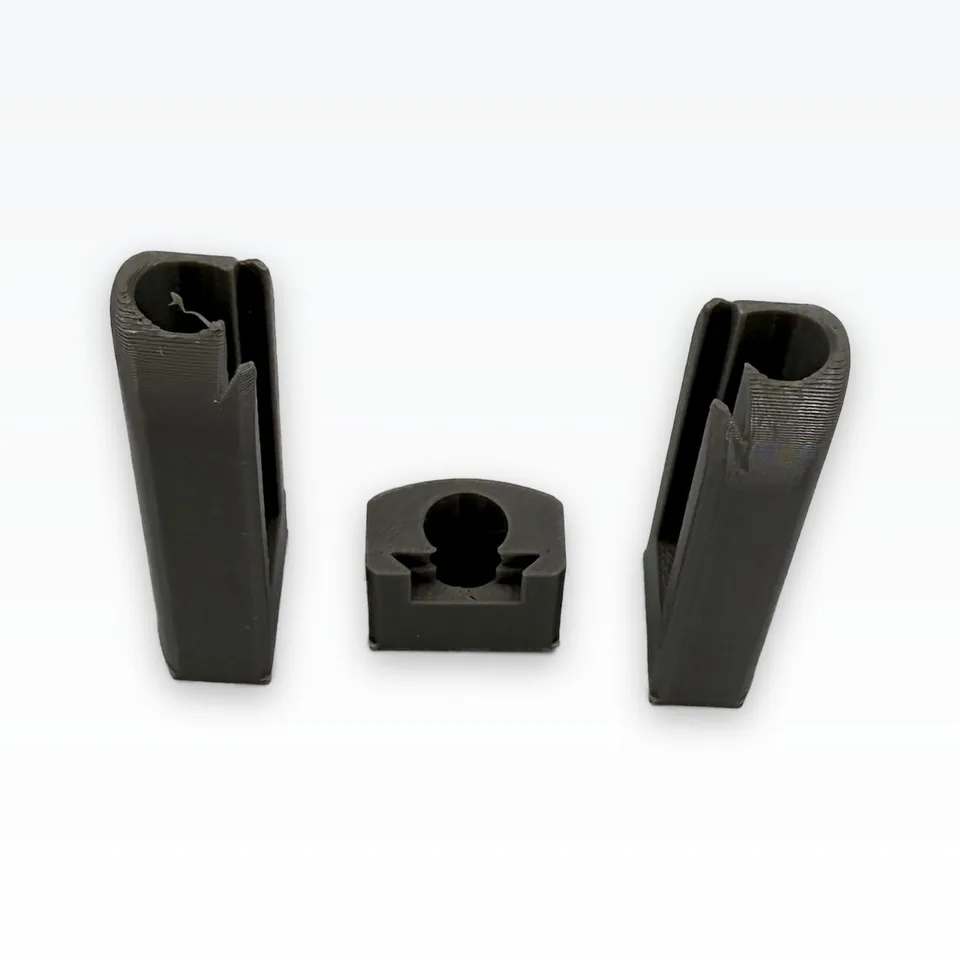
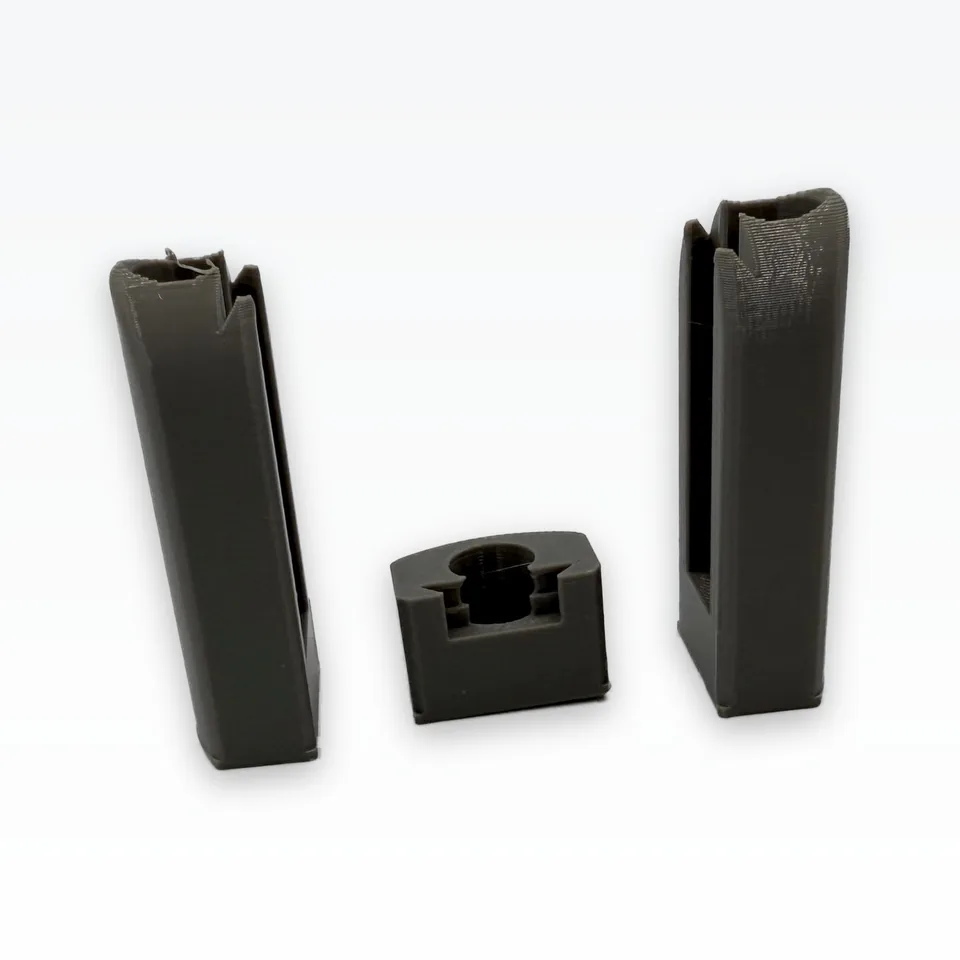
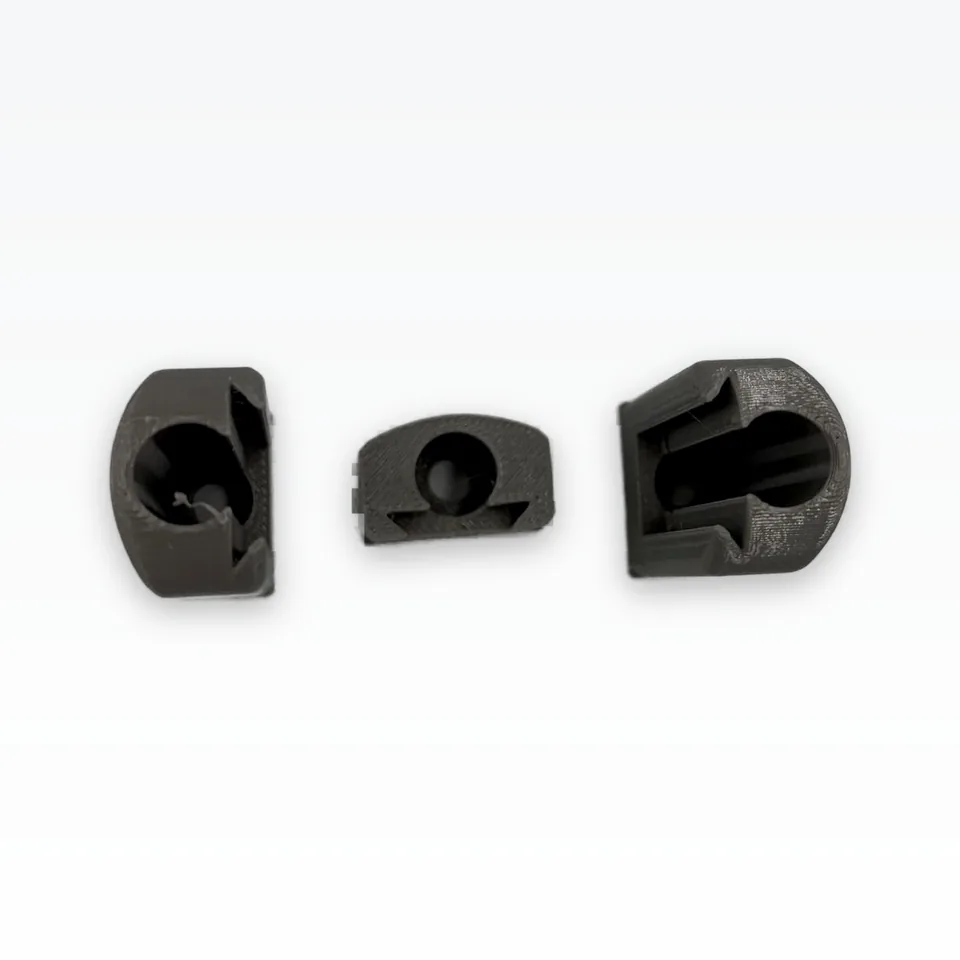
Renders on this page are of our own demo design, not a customer job. The photos are of our first fit prototype of that design, printed in grey PETG; production fingers are PETG-CF with TPU pads.
From your part to fingertips on the gripper
Send gripper + part
Tell us the gripper (for example a Robotiq 2F-85) and send a STEP, STL or photos with sizes of the part it has to pick.
Design + 3D preview
We model the fingertips to your part and the gripper’s mounting pattern and send a link to spin the 3D model before anything prints.
Prototype in 2–3 days
A fit-check set printed in PETG-CF, or PETG for a quick first fit, with a mount test coupon so the bolt pattern is confirmed on your gripper.
Production
The approved design in PETG-CF or carbon-fibre nylon from our workshop, or SLS PA12 through our partner network for larger runs.
Turnaround: design and 3D preview normally 1–2 business days after we have the files, prototype set printed and shipped in 2–3 days, production timing confirmed with the quote. Every job is quoted within 1 business day and nothing prints before you approve the preview and the price.
Which grippers can we design for?
Any gripper with a published fingertip interface. Names describe the mounting pattern our parts fit; we are not affiliated with any gripper maker.
| Gripper | Fingertip interface | Status |
|---|---|---|
| Robotiq 2F-85 / 2F-140 | Same finger holder on both: M5 screw + two Ø2 dowel pins, 16.2 × 17.8 mm end face. Designed from Robotiq’s public instruction manual. | Demo set designed |
| Robotiq Hand-E | Fingertip holder with M4 screws and dowel pins, per Robotiq’s public custom-fingertip guide. | On request |
| OnRobot RG2 / RG6 | Fingertip interface from OnRobot’s published drawings. | On request |
| Schunk parallel grippers | Finger interface from Schunk’s published drawings for the model you use. | On request |
| Other grippers | Send a STEP or drawing of the finger, or post us a fingertip to measure. | On request |
Which material for gripper fingers?
Stiff, light bodies and soft replaceable pads. Tell us the part, the cell temperature and the cycle count and we recommend one.
| Material | Good for | Status |
|---|---|---|
| PETG-CF | Rigid finger bodies: stiff, light, matte. Our default for fingertips. | On request |
| TPU 95A | Replaceable grip pads, soft jaws, bumpers. | Printing today |
| CF-nylon (PAHT-CF) | Stiffer or warmer cells; longer fingers. | On request |
| SLS PA12 | Production fingers and fixtures in quantity. | Via our partner network |
| PETG | Quick fit-check prototypes and jigs. | Printing today |
| Resin (Formlabs Form 4) | Small, fine-detail pads and inserts. | Coming soon, not available yet |
We don’t certify printed parts as food-safe or for any safety function. If a pad touches produce or the fingers are part of a safety assessment, say so and we design and document for it.
What else we make for robot cells
Part nests & locators
Nests, V-blocks and locators that present a part to the gripper the same way every cycle.
EOAT adapters & spacers
Adapter plates between tool flange, gripper and sensors, with your bolt patterns.
Camera & sensor brackets
Brackets and hoods for vision cameras and sensors on the arm or over the cell.
Cable guides & dress packs
Clips, guides and strain reliefs that follow the arm.
Jaws & soft inserts
TPU inserts and soft jaws for delicate, irregular or finished parts.
Spares from your file
Fingertips and pads are wear items: we reprint them from the approved file when you need more.
Common questions
Which grippers can you design fingertips for?
Any parallel or adaptive gripper with a published fingertip interface. Robotiq 2F-85 and 2F-140 (same finger holder: one M5 screw and two 2 mm dowel pins) and Hand-E are designed from the maker’s public drawings; OnRobot RG2/RG6, Schunk and others from their published drawings or a STEP of the finger. If no drawing exists we measure a fingertip you send us.
Can the soft pads be replaced without tools?
Yes. On our fingertips the TPU 95A pad slides into a dovetail on the rigid body and clicks into a retention groove, so there is no glue and a worn pad swaps in seconds. Pads can be printed in different hardnesses or with different contours for the same body.
What gripping force are the fingertips good for?
Fingertips are designed within the gripper maker’s published limits for fingertip size, mass and moment, and the pad geometry is chosen to keep the grip below the gripper’s equilibrium line for a stable grasp. They do not change the gripper’s rated force. We do not certify parts for any safety function; validate them on your cell before production.
How much does a custom fingertip set cost?
Custom fingertips are quoted per job within 1 business day, based on the design work, the material and the quantity. Plain print jobs from your own STL files can be priced instantly at formada3d.com/quote.
Which material should the fingers be made of?
PETG-CF for stiff, light finger bodies in most cells; carbon-fibre nylon (PAHT-CF) where heat or higher stiffness matters; SLS PA12 through our partner network for production runs. Pads are TPU 95A. Fit-check prototypes can be printed in plain PETG. We do not certify printed parts as food-safe.
What files do you need?
A STEP of the part is ideal; an STL or photos with measurements also work. For the gripper, its model name is enough when the fingertip interface is public; otherwise a STEP or drawing of the finger. NDAs are available on request.
How fast is a prototype?
The design and 3D preview normally take 1–2 business days after we have the files; the prototype set prints and ships in 2–3 days. We reply to enquiries within 24 hours.
Tell us the gripper and the part.
Use the enquiry form or email [email protected] with the gripper model and a STEP, STL or photos of the part. You get a quote within 1 business day and a 3D preview before anything prints.
Last updated 13 October 2026.