 Formada3D
Robot flange camera and sensor mount: ISO 9409-1 collar (50-4-M6 / 31.5-4-M5) with a tilting 1/4-20 or M12/M18 head
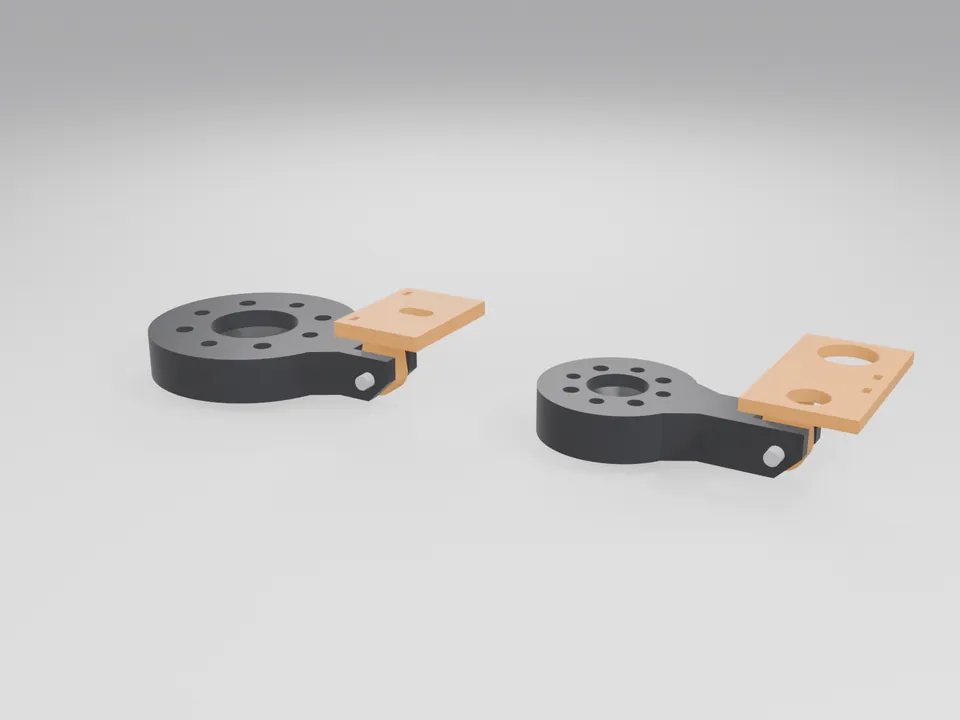
A camera and sensor mount for robot wrists. A 16 mm collar fits between the robot's ISO 9409-1 tool flange and your gripper: the tool's own screws pass through it, a pilot boss and dowel pins locate it, and your tool still centres in the collar's own recess. An arm on the collar carries a tilting head beside the tool: a 1/4-20 camera head for USB and machine-vision cameras, or a sensor head for M12 and M18 barrel sensors. The head tilts from 20 degrees toward the tool to 60 degrees away on one M5 bolt. Two sizes: 50-4-M6 (fits UR e-Series, Franka Research 3 and ABB GoFa CRB 15000, per their published flange drawings) and 31.5-4-M5 (fits ABB IRB 1200). From A$8; 50 size with a camera head A$11.95. Printed to order in PETG in our Melbourne workshop.
From A$8 for the 31.5 collar with one head. Printed to order in Melbourne and shipped Australia-wide; we confirm the final price and lead time before anything is printed.
On the quote page choose Request a quote (no file needed) and name this part and the option you want.
Order status. Every robot interface number comes from ISO 9409-1 and the robot makers' own flange drawings. A free 3 mm pilot coupon can be printed first so you can check the fit on your flange before the collar is made.
What does it look like in use?
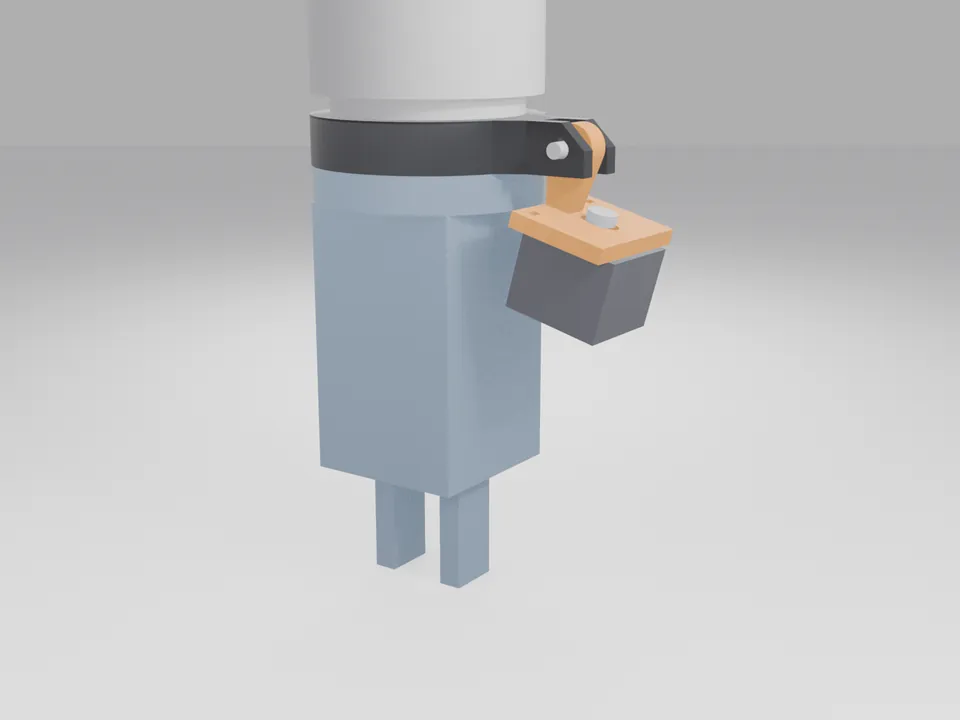
Renders are computer images of our own design, made from the same model we print. This family is made to order: real photos of our first prints are coming.
Specifications: material, size and what it fits
| Spec | Detail |
|---|---|
| Collar 50-4-M6 | 76 mm disc, 16 mm thick. Pilot boss 31.2 mm into the robot's 31.5 H7 recess; 31.8 mm recess for the tool's pilot; 4 x 6.6 mm holes on the 50 mm bolt circle for the tool's M6 screws; 4 dowel holes for 6 mm pins at 0, 90, 180 and 270 degrees so the arm can point four ways; 20 mm cable bore |
| Collar 31.5-4-M5 | 52 mm disc, 16 mm thick. Pilot boss 19.7 mm into the 20 H7 recess; 20.3 mm tool recess; 4 x 5.5 mm holes on the 31.5 mm circle; 4 dowel holes for 5 mm pins; 12 mm bore |
| Fits | Tool flanges built to ISO 9409-1-50-4-M6: for example UR e-Series (UR3e, UR5e, UR10e, UR16e), Franka Research 3 (DIN ISO 9409-1-A50) and ABB GoFa CRB 15000, per their published flange drawings. ISO 9409-1-31.5-4-M5: for example ABB IRB 1200. Check your robot's flange drawing before ordering |
| Camera head | 44 x 32 x 5 mm plate with a 6.7 mm slot (plus or minus 3 mm) for one 1/4-20 camera screw (the standard tripod thread), two cable-tie slots |
| Sensor head | 64 x 34 x 4 mm plate with a 12.5 mm hole for M12 and an 18.5 mm hole for M18 barrel sensors (inductive, capacitive, photoelectric), clamped by the sensor's own nuts |
| Depth cameras | The pivot is the same as our depth-camera tilt mount, so its D435-type (2 x M3 at 45 mm) and D455-type (2 x M4 at 95 mm) brackets fit the collar too |
| Tilt and clearance | Head 50-80 mm from the flange axis. Tilt range checked in 1 degree steps: camera head 25 degrees toward the tool to 60 away, sensor head 20 toward to 60 away. Keep the tool inside about 46 mm radius on the arm side for its first 60 mm |
| Material and print | PETG. Collars 4 walls and 40 % infill because the tool's load passes through them; heads 2 walls and 5 %. PETG-CF or PA-CF on request. Printed without supports |
| Hardware | Not included. Tool screws: 4 x M6 (or M5) as long as your tool flange + 16 mm + 6-8 mm thread (UR: no deeper than 8 mm into the flange). 2 dowel pins 6 x 12 (or 5 x 10). Pivot: M5 x 25 + nyloc nut and washers. Camera: 1/4-20 x 3/8 in screw |
| Weight | 50 collar about 56 g, 31.5 collar about 35 g, heads 7-8 g |
Universal Robots, UR, Franka, ABB, GoFa and RealSense are trademarks of their owners. This is our own design and an independent accessory, not affiliated with or endorsed by them. Robot names are given only to describe fit.
How much does it cost?
Guide prices for printed parts, in Australian dollars. Shipping is extra; we confirm the final price, including any business minimum, before printing. Bulk and custom sizes are quoted per job.
| Option | From |
|---|---|
| 31.5 collar + camera head or sensor head | A$8 |
| 31.5 collar + both heads | A$8.95 |
| Collar only, 31.5-4-M5 | A$8 |
| Collar only, 50-4-M6 | A$9.95 |
| 50 collar + 1/4-20 camera head | A$11.95 |
| 50 collar + M12/M18 sensor head | A$11.95 |
| 50 collar + depth-camera bracket (D435 or D455 type) | A$11.95 |
| 50 collar + both heads | A$12.95 |
| Pilot fit coupon (3 mm disc) | Free with an order |
Who it's for
Robotics integrators, university and TAFE cobot labs, and automation teams who want a wrist camera or a sensor on the robot for vision, inspection or pick-and-place trials without machining a bracket first.
Safety & use
Installation & use. Designed for the uses described on this page only. Fixings are not included: use the sizes listed, check they are tight before use, and check the parts regularly for wear or damage. Not for safety-critical or overhead load-bearing use. Damage caused by misuse, modification or overloading isn't a fault in the product.
Robot tool flanges. The collar sits between the robot flange and your tool, so the tool's load passes through it. It is for cameras, sensors and light tools (up to about 1 kg) in prototyping, labs and teaching, not for production payloads. Follow your robot maker's tool-mounting instructions and your own risk assessment, tighten the tool screws evenly by hand (about 3-4 N m on M6, 2-3 N m on M5), check them after the first hours of running and before each use, and use a metal spacer for production. Made to the ISO 9409-1 hole pattern; not certified to it or to any other standard.
Cables and clearance. Tie camera and sensor cables to the arm so they cannot catch on the robot's joints, check the head's clearance to your tool through the whole program at slow speed first, and keep the pivot bolt tight. Use the screw lengths listed: a longer camera screw can damage the camera.
This doesn't affect your rights under the Australian Consumer Law.
Common questions
Which robots does the flange camera mount fit?
Robots with an ISO 9409-1-50-4-M6 tool flange, for example UR e-Series, Franka Research 3 and ABB GoFa CRB 15000 according to their published flange drawings, take the 50 collar. Robots with ISO 9409-1-31.5-4-M5, for example ABB IRB 1200, take the 31.5 collar. Check the bolt circle, recess and dowel size on your robot's flange drawing before ordering.
How does a sandwich collar mount?
It goes between the robot flange and your tool. A pilot boss and a dowel pin locate it on the robot, the tool's pilot sits in the collar's own recess with a second dowel, and the tool's own screws pass through the collar into the robot. Use screws 16 mm longer than before, and keep within your robot's thread depth (UR: no deeper than 8 mm).
Which cameras and sensors fit?
The camera head takes any camera with a 1/4-20 tripod socket, such as USB webcams and many machine-vision cameras. The sensor head takes M12 and M18 threaded-barrel sensors held by their own nuts. Our depth-camera brackets for D435-type and D455-type cameras fit the same pivot.
Can I aim the camera at the gripper fingers?
Yes. The head tilts on one M5 bolt from 20-25 degrees toward the tool to 60 degrees away, and the collar has four dowel holes so the arm can point in any of four directions around the flange, away from cables or wide fingers.
Can a 3D printed collar carry my gripper?
It is meant for cameras, sensors and light tools up to about 1 kg in labs and prototyping. The collars print in PETG with 4 walls and 40 % infill because the tool's load passes through them. Hand-tighten the tool screws evenly, re-check them after the first hours, and use a metal spacer for production payloads.
Does it work with the Franka Hand?
The 50 collar fits the Franka Research 3 flange pattern. The Franka Hand takes power through the arm's flange connector, and Franka's manual says to fit an extension cable when equipment goes between the hand and the flange.
How do I order?
Use Get a quote and choose Request a quote, naming the collar size (50-4-M6 or 31.5-4-M5), the head (camera, sensor or a depth-camera bracket) and the quantity. We confirm the price and lead time before anything is printed.
More from the parts catalogue
Sensor brackets, suction-cup arms and ISO 9409-1 tool-flange adapters for 2020 extrusion
Limit-switch and sensor brackets, vacuum-cup arms and ISO 9409-1 (50-4-M6, 31.5-4-M5) flange adapters, in PETG.
Tilting depth-camera mount for 2020 extrusion (fits RealSense D435 / D435i and D455 rear mounting points)
A 2020 T-nut base and a camera bracket that tilts from 30 degrees down to 60 degrees up on one M5 bolt. 45 mm and 95 mm brackets.
Adaptive soft gripper finger kit (fin-ray style, TPU)
Soft TPU fingers that wrap around eggs, fruit and bottles. Three sizes, one M3 mount.
Last updated 17 October 2026.