 Formada3D
SO-101 robot arm wrist camera mount for 32 x 32 mm USB camera boards (PETG)
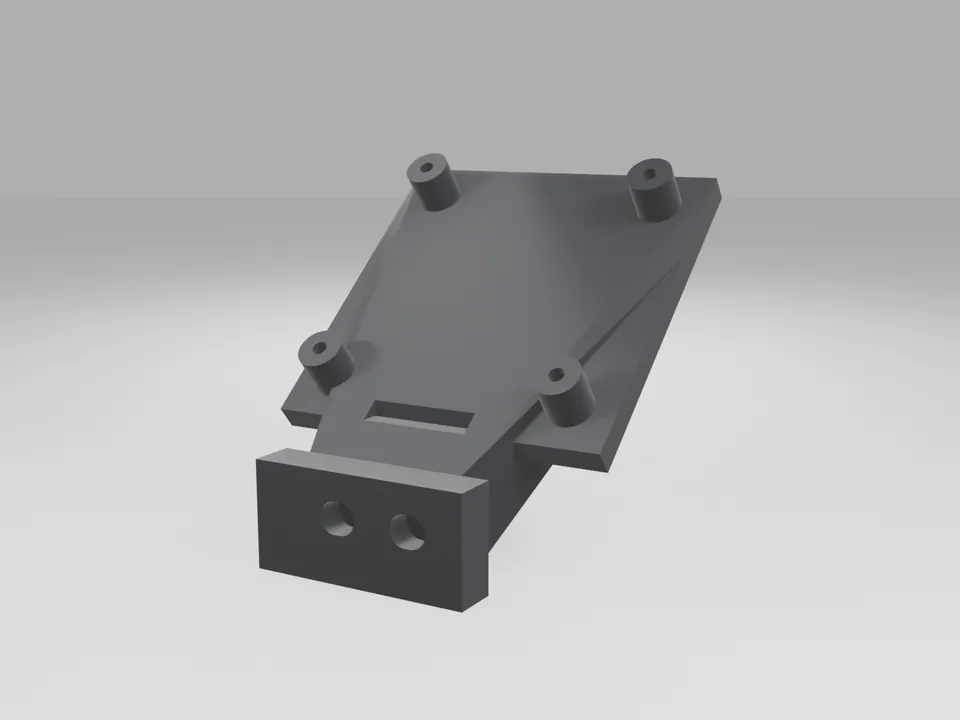
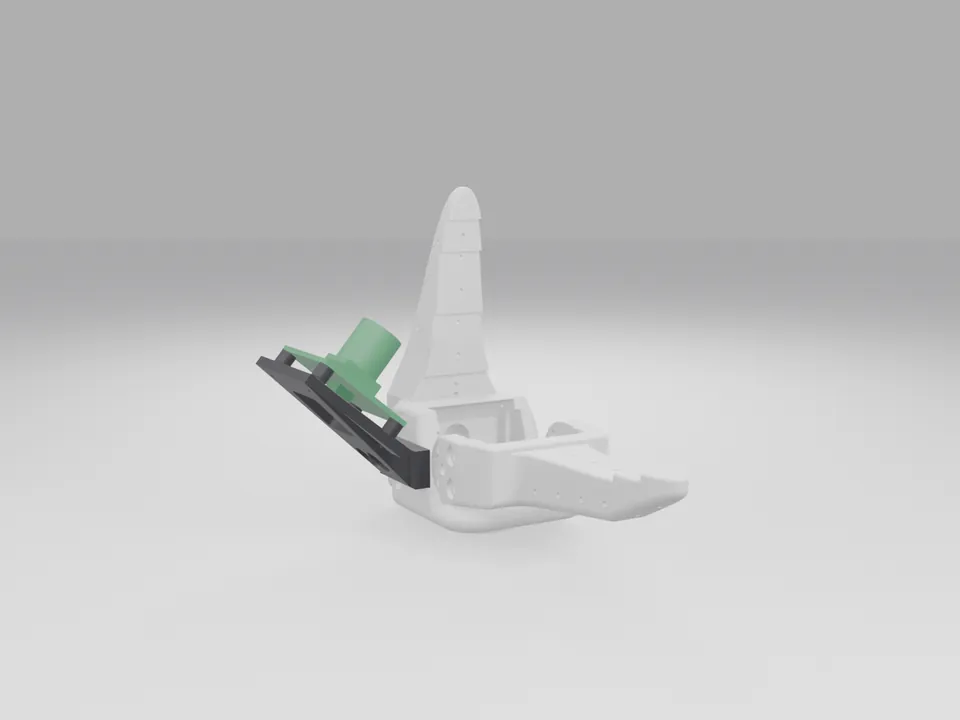
A one-piece PETG bracket that puts a camera on the wrist of an SO-101 follower arm for LeRobot data collection. It bolts to the front face of the fixed jaw with two M3 screws into the jaw's own two M3 nut traps, and holds a 32 x 32 mm USB camera board (28 x 28 mm hole pitch) on four M2 standoffs, angled 40 degrees off the finger axis so the lens looks down the fingers at the grasp zone. A window behind the board leaves room for the rear connector, and a cable-tie slot keeps the lead tidy. The jaw interface is measured from the official open-source SO-101 part files. Printed to order in our Melbourne workshop.
From A$8 for the wrist camera mount in PETG. Printed to order in Melbourne and shipped Australia-wide; we confirm the final price and lead time before anything is printed.
On the quote page choose Request a quote (no file needed) and name this part and the option you want.
Order status. The jaw interface is measured from the official SO-101 files. Camera boards do not publish their hole size (only the 28 x 28 mm pitch), so your first order includes the free coupon: bolt it to your jaw and screw your board on before we print the final mount. Check the arm's full wrist flex by hand after fitting.
What does it look like in use?
Renders are computer images of our own design, made from the same model we print. This family is made to order: real photos of our first prints are coming.
Specifications: material, size and what it fits
| Spec | Detail |
|---|---|
| Material | PETG (black), 0.24 mm layers on a 0.6 mm nozzle, 3 walls, 5 % infill (almost all wall; light camera, no structural load), no supports. Jaw contact face prints on the bed so it is flat and true |
| Size | 38 x 41 x 41 mm, about 8.4 g |
| Jaw interface | 2 x 3.4 mm holes 8.1 mm apart, slotted +-0.3 mm, counterbored 6.2 mm x 2.0 deep, matching the two M3 nut traps in the SO-101 follower's fixed jaw (measured from the official SO-ARM100 release). Everything stays behind the jaw face; the moving jaw was swept through +-120 degrees with zero contact |
| Camera plate | Four M2 standoffs (1.7 mm pilots) on a 28 x 28 mm square for 32 x 32 mm USB camera boards, plate angled 40 degrees down the fingers, rear connector window, cable-tie slot |
| Fits | SO-101 / SO-ARM101 follower arms built from the official open-source files, and 32 x 32 mm USB camera boards with a 28 x 28 mm hole pitch (board size and pitch from camera makers' product pages) |
| Hardware | Not included: 2 x M3 x 10 socket-head screws (into the jaw's own nuts) and 4 x M2 x 6 screws for the board. Camera not included |
| Fit coupon | Free with an order: the jaw pad and a 28 x 28 standoff square in one 4.6 g piece. Check the screws and your board's holes (some boards use M2.5) before the final print |
SO-101 / SO-ARM100 is an open-source design by The Robot Studio (Apache License 2.0); LeRobot and Hugging Face are trademarks of their owners. This mount is our own design and is not affiliated with or endorsed by them.
How much does it cost?
Guide prices for printed parts, in Australian dollars. Shipping is extra; we confirm the final price, including any business minimum, before printing. Bulk and custom sizes are quoted per job.
| Option | From |
|---|---|
| Wrist camera mount, PETG | A$8 |
| 2 mounts (two arms) | A$8 |
| Fit coupon (jaw pad + standoff square) | Free with an order |
| M2.5 board holes or another board size | Quoted from your board's drawing, usually no extra charge |
Who it's for
LeRobot and SO-101 owners collecting training data with a wrist camera, university and school robotics labs, and anyone who bought an SO-101 kit without a 3D printer.
Safety & use
Installation & use. Designed for the uses described on this page only. Fixings are not included: use the sizes listed, check they are tight before use, and check the parts regularly for wear or damage. Not for safety-critical or overhead load-bearing use. Damage caused by misuse, modification or overloading isn't a fault in the product.
Robots. Powered joints can pinch and move unexpectedly. Keep fingers, hair and cables clear while powered, check the full range of motion by hand after fitting, and use the screw lengths listed on this page. PETG softens near 70 degrees C. A printed bracket is for hobby, education, research and prototype loads.
This doesn't affect your rights under the Australian Consumer Law.
Common questions
Which arm does it fit?
The SO-101 (SO-ARM101) follower arm built from the official open-source files. It bolts to the front face of the fixed jaw with two M3 x 10 screws into the two M3 nuts that sit in the jaw's own nut traps, so nothing on the arm is drilled or changed.
Which cameras fit?
32 x 32 mm USB camera boards with a 28 x 28 mm hole pitch, the common size for small UVC camera modules. The four standoffs take M2 screws; if your board has M2.5 holes, tell us and we enlarge the pilots.
Does it hit the gripper?
No. Every part of the mount stays behind the jaw face, and we swept the moving jaw through +-120 degrees and the wrist roll through a full turn in the model with zero contact. Extreme wrist pitch against the forearm was not modelled, so check the full range by hand after fitting.
Why is the camera angled?
The plate tilts the board 40 degrees off the finger axis, so the lens looks down the fingers at the grasp zone, which is what LeRobot policies learn from.
How do I order?
Use Get a quote and choose Request a quote, naming the wrist camera mount and quantity. We confirm the price and lead time before anything is printed. The arm's printed part sets are on their own page.
More from the parts catalogue
Adaptive soft gripper finger kit (fin-ray style, TPU)
Soft TPU fingers that wrap around eggs, fruit and bottles. Three sizes, one M3 mount.
Servo bracket and camera mount kit for 2020 extrusion
Standard-servo bracket and a camera mount for 2020 aluminium extrusion, in PETG.
Sensor brackets, suction-cup arms and ISO 9409-1 tool-flange adapters for 2020 extrusion
Limit-switch and sensor brackets, vacuum-cup arms and ISO 9409-1 (50-4-M6, 31.5-4-M5) flange adapters, in PETG.
Last updated 15 October 2026.