 Formada3D
Gripper finger blanks, TPU grip pads and robot arm cable clips: fits Robotiq 2F-85 / 2F-140 and OnRobot RG2
Printed end-of-arm tooling for robot integrators and labs. The finger blanks bolt straight onto two common parallel grippers: they fit Robotiq 2F-85 and 2F-140 finger holders (one M5 screw plus the gripper's own dowel pins) and OnRobot RG2 fingers (the blank slides over the finger end and takes two M4 screws), using the makers' published finger drawings. Each blank is 60 mm long with a flat face and a pad slot, or a 120 degree V-groove for round parts, and has trim marks so you can cut, file or drill it to your part. Clip-on TPU grip pads (ribbed or V) slide into the slot of any flat blank; stick-on pads suit faces you have shaped. Cable guide clips sit on any round arm link from 25 to 110 mm with a 25 mm strap and snap-hold an 8 or 13 mm cable. Pair of blanks from A$8, blanks with pads A$12.95-13.95, 4 clips A$8.95. Printed to order in our Melbourne workshop.
From A$8 for the pair of RG2 blanks, a pad pair or 4 stick-on pads. Printed to order in Melbourne and shipped Australia-wide; we confirm the final price and lead time before anything is printed.
On the quote page choose Request a quote (no file needed) and name this part and the option you want.
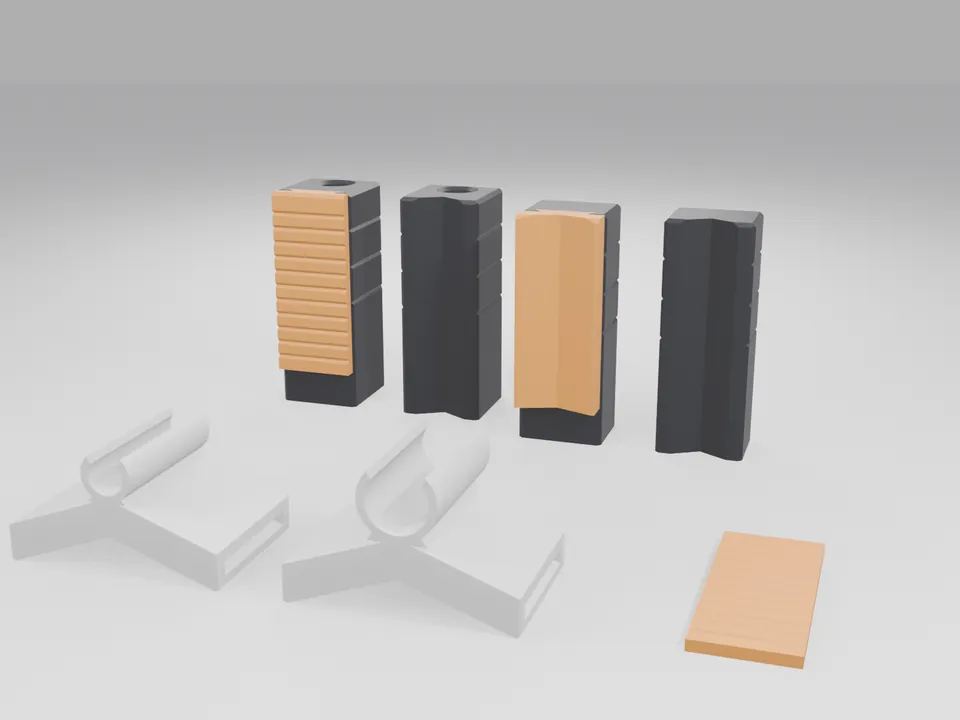
Order status. The mounting ends come from the gripper makers' published finger drawings, but we have not yet fitted them to a real gripper. Each first order comes with free fit coupons: a short stub of the blank's mount to bolt onto your gripper, pad slices in four slide fits, and cable rings. Print or ask for those first; the full set follows once the stub fits.
Need a finished custom fingertip shaped to your part instead of a blank? See our custom robot gripper fingers service. Soft adaptive fingers: fin-ray style gripper fingers. Camera or sensor on the wrist: robot flange camera and sensor mount.
What does it look like in use?
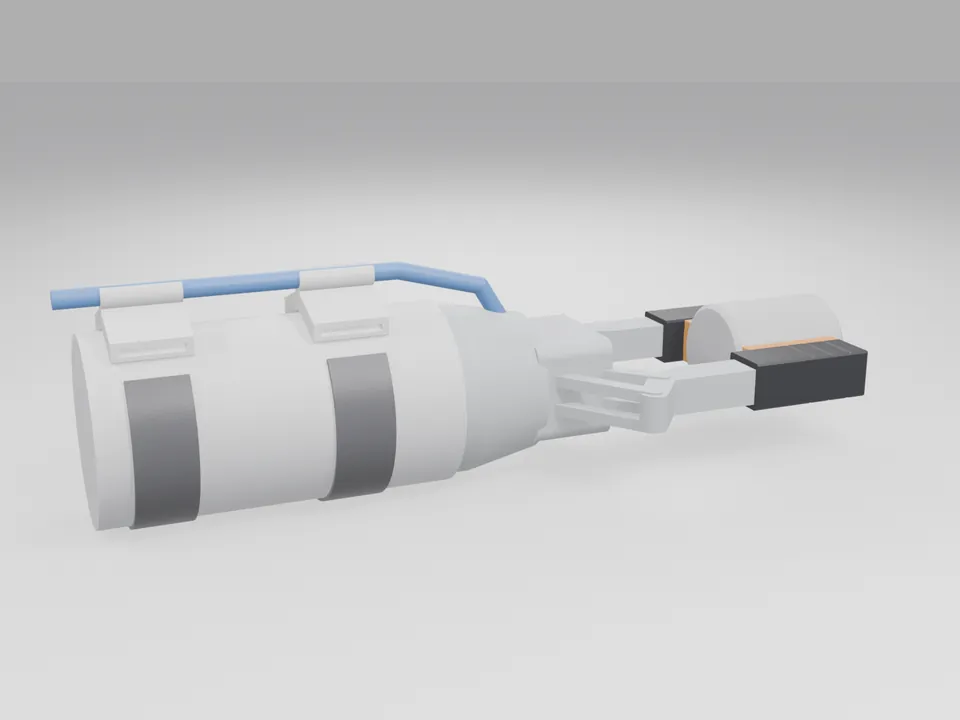
Renders are computer images of our own design, made from the same model we print. This family is made to order: real photos of our first prints are coming.
Specifications: material, size and what it fits
| Spec | Detail |
|---|---|
| Blank, fits 2F-85 / 2F-140 | 60 x 22 x 22.7 mm. Mount face for the 16.2 x 17.8 mm finger holder: one M5 x 12 screw goes in from the tip down a 9.4 mm access bore (4 mm hex key), plus 2 dowel holes for the gripper's own 2 mm pins. Face 2 mm in front of the standard fingertip's grip plane. Flat with an 11 mm dovetail pad slot, or a 120 degree V-groove 14 mm wide |
| Blank, fits RG2 | 60 x 22 x 17.7 mm. Pocket for the 11.6 x 7 mm finger end (0.2 mm clearance per side) and 2 x M4 x 8 screws from the back into the finger's M4 threads. Face 7.5 mm in front of the finger. Flat with the same pad slot, or the 120 degree V-groove |
| Trimming and machining | Trim marks at 30, 40 and 50 mm from the mount. Printed with 4 walls (about 2.5 mm solid skin), so up to about 2 mm can be filed or milled off a face and holes drilled for your part. Deeper machining: ask for 100 % infill. Or send us the part and we shape the face for you |
| Grip pads (TPU 95A) | Clip-on ribbed pad or clip-on V pad (140 degree, for round parts about 30-60 mm), 21 x 50 mm, slide into the slot of any flat blank and snap home on a small ridge, no glue. Stick-on ribbed pad 50 x 21 x 2.5 mm for double-sided tape. Free pad fit coupons in 4 slide fits |
| Cable guide clips | 48 x 32 mm. 140 degree V seat sits on any round arm link or tube 25-110 mm across; a 26 x 3 mm tunnel takes a 25 mm hook-and-loop strap or two cable ties; snap channel for an 8 mm or 13 mm cable or bundle (6-16 mm on request). Free ring coupon to pick the size |
| Fits | Robotiq 2F-85 and 2F-140 finger holders (manual section 5.1.3) and OnRobot RG2 fingers (datasheet v1.8, fingertip drawing). Other parallel grippers: send the finger drawing and we model the mount |
| Material and print | Blanks PETG with 4 walls and 20 % infill (load-bearing fingers, plus the solid skin for filing); PETG-CF or PA-CF on request. Pads TPU 95A. Clips PETG, 2 walls and 5 %. Printed without supports |
| Hardware | Not included. 2F-85 / 2F-140: 1 x M5 x 12 socket head screw per blank, plus the gripper's own 2 mm dowel pins. RG2: 2 x M4 x 8 button head screws per blank. Clips: a 25 mm hook-and-loop strap or 2 cable ties each |
| Weight | Blank 17-22 g, clip-on pad 5 g, stick-on pad 3 g, cable clip 11-12 g |
Robotiq is a trademark of Robotiq Inc. and OnRobot and RG2 are trademarks of OnRobot A/S. This is our own design and an independent accessory, not made, approved or endorsed by them. Gripper names are given only to describe fit.
How much does it cost?
Guide prices for printed parts, in Australian dollars. Shipping is extra; we confirm the final price, including any business minimum, before printing. Bulk and custom sizes are quoted per job.
| Option | From |
|---|---|
| Pair of RG2 blanks, flat or V-groove | A$8 |
| Pair of 2F-85 / 2F-140 blanks, flat or V-groove | A$8.95 |
| Pair of RG2 flat blanks + 2 clip-on pads | A$12.95 |
| Pair of 2F-85 / 2F-140 flat blanks + 2 clip-on pads | A$13.95 |
| Clip-on TPU pads, pair (ribbed or V) | A$8 |
| Stick-on TPU pads, 4 | A$8 |
| Cable guide clips x4, 8 mm channel | A$8.95 |
| Cable guide clips x4, 13 mm channel | A$9.95 |
| Cable guide clips x10, 8 mm channel | A$21.95 |
| Fit coupons (mount stub, pad slices, cable rings) | Free with an order |
Who it's for
Robotics integrators, cobot labs at universities and TAFEs, and automation teams who need a set of fingers for a new part this week, spare pads, or tidy cable runs on a robot arm, without waiting for machined jaws.
Safety & use
Installation & use. Designed for the uses described on this page only. Fixings are not included: use the sizes listed, check they are tight before use, and check the parts regularly for wear or damage. Not for safety-critical or overhead load-bearing use. Damage caused by misuse, modification or overloading isn't a fault in the product.
Gripper tooling. Custom fingers change your gripper's payload, force and moment limits: check the gripper maker's limits for finger length and mass (the 2F-85 / 2F-140 allows custom tips up to 100 mm), test at low force and speed first, and include the fingers in your cell's risk assessment. Not a safety component, and not for lifting over people. Tighten the screws by hand with the sizes listed and check them and the pads regularly. Printed PETG and TPU are not sold as food-contact parts.
Cable clips. For light signal and power cables on robot arms and frames. Route cables so they cannot snag the robot's joints through its full motion, leave slack across every joint, and check the straps regularly. Not for lifting or load-bearing use.
This doesn't affect your rights under the Australian Consumer Law.
Common questions
Which grippers do the finger blanks fit?
Robotiq 2F-85 and 2F-140 finger holders (both use the same holder) and OnRobot RG2 fingers, built from the makers' published finger drawings. For the 2F-85 / 2F-140, one M5 screw and the gripper's own two dowel pins hold each blank; for the RG2, the blank slides over the finger end and takes two M4 screws from the back. Other parallel grippers can be modelled from their finger drawing on request.
What is a finger blank for?
A blank is a plain rigid finger you finish yourself: cut it to length at the trim marks, file or mill a pocket the shape of your part, or drill it for a stop or a sensor. It prints with 4 walls, so about 2 mm can come off a face without opening the infill. If you would rather not shape it, send us the part and we design a finished fingertip instead.
How do the TPU grip pads attach?
The clip-on pads have a dovetail that slides into the slot along the face of any flat blank and snaps home on a small ridge near the root, with no glue. The same pads fit both the 2F-85 and RG2 blanks. Choose ribbed for flat parts or V for round parts about 30-60 mm. Stick-on pads go on a face you have shaped, with double-sided tape.
Which robot arms do the cable clips fit?
Any round arm link or tube from 25 to 110 mm across. The clip has a wide V seat that sits on two lines on any diameter in that range, and a 25 mm hook-and-loop strap or two cable ties go through its tunnel and around the link. The channel snap-holds an 8 mm or 13 mm cable or bundle; other sizes from 6 to 16 mm on request.
Why are fit coupons included?
Each mount uses one size we could not confirm from the drawings alone: where the 2F-85 holder's hole line sits, and which way the RG2 finger faces. A free 15-28 mm stub of the mount, bolted onto your gripper, confirms both in under half an hour of printing before the full set is made. The pad and cable coupons pick the slide fit and channel size.
How strong are printed fingers?
The blanks print in PETG with 4 walls and 20 % infill. At the 2F-85's maximum 235 N grip force the bending stress at the blank's root is under 4 MPa, well inside PETG's strength. For heavy or hot parts ask for PETG-CF or PA-CF. Always respect the gripper maker's payload and finger-length limits.
How do I order?
Use Get a quote and choose Request a quote, naming the gripper (2F-85 / 2F-140 or RG2), flat or V-groove, the pads and the number of pairs, or the cable clip channel size and quantity. We confirm the price and lead time before anything is printed.
More from the parts catalogue
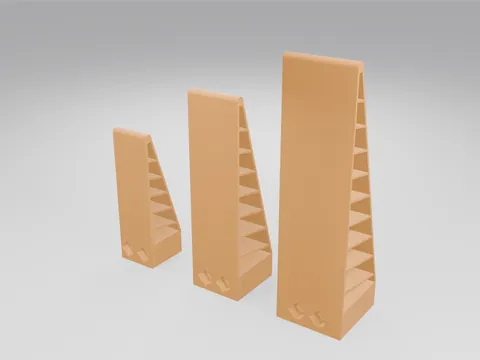
Adaptive soft gripper finger kit (fin-ray style, TPU)
Soft TPU fingers that wrap around eggs, fruit and bottles. Three sizes, one M3 mount.
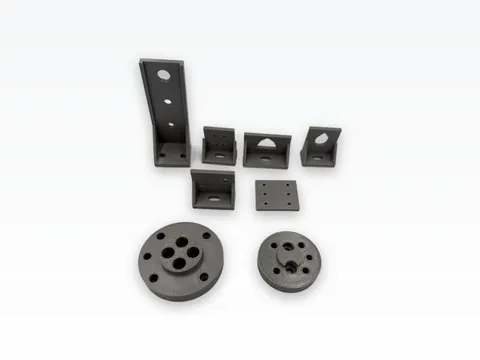
Sensor brackets, suction-cup arms and ISO 9409-1 tool-flange adapters for 2020 extrusion
Limit-switch and sensor brackets, vacuum-cup arms and ISO 9409-1 (50-4-M6, 31.5-4-M5) flange adapters, in PETG.
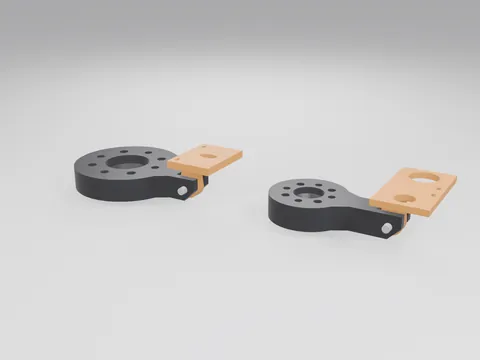
Robot flange camera and sensor mount: ISO 9409-1 collar (50-4-M6 / 31.5-4-M5) with a tilting 1/4-20 or M12/M18 head
A collar that fits between an ISO 9409-1 robot flange and your tool, with a tilting head for a 1/4-20 camera or M12/M18 sensors.
Last updated 17 October 2026.